About this notebook
Why this notebook is called Merry'n'Pippin: two robot arms named after Tolkien’s trouble-prone pair, and what I write here.
I’m Kris. This is a lab notebook for robot learning on a small budget: hardware notes, datasets, training runs, and the experiments that don’t work.
The two arms on the bench are named after Merry and Pippin from The Lord of the Rings. Tolkien’s pair are close friends, mischievous, curious, and frequently in trouble together — almost a comic duo early on, then something more serious. Merry is generally the more sensible, planning one. Pippin is more impulsive, and particularly good at accidentally causing problems. If something questionable is happening, there’s a decent chance they are both involved.
That is a pretty good cultural shorthand for this bimanual setup:
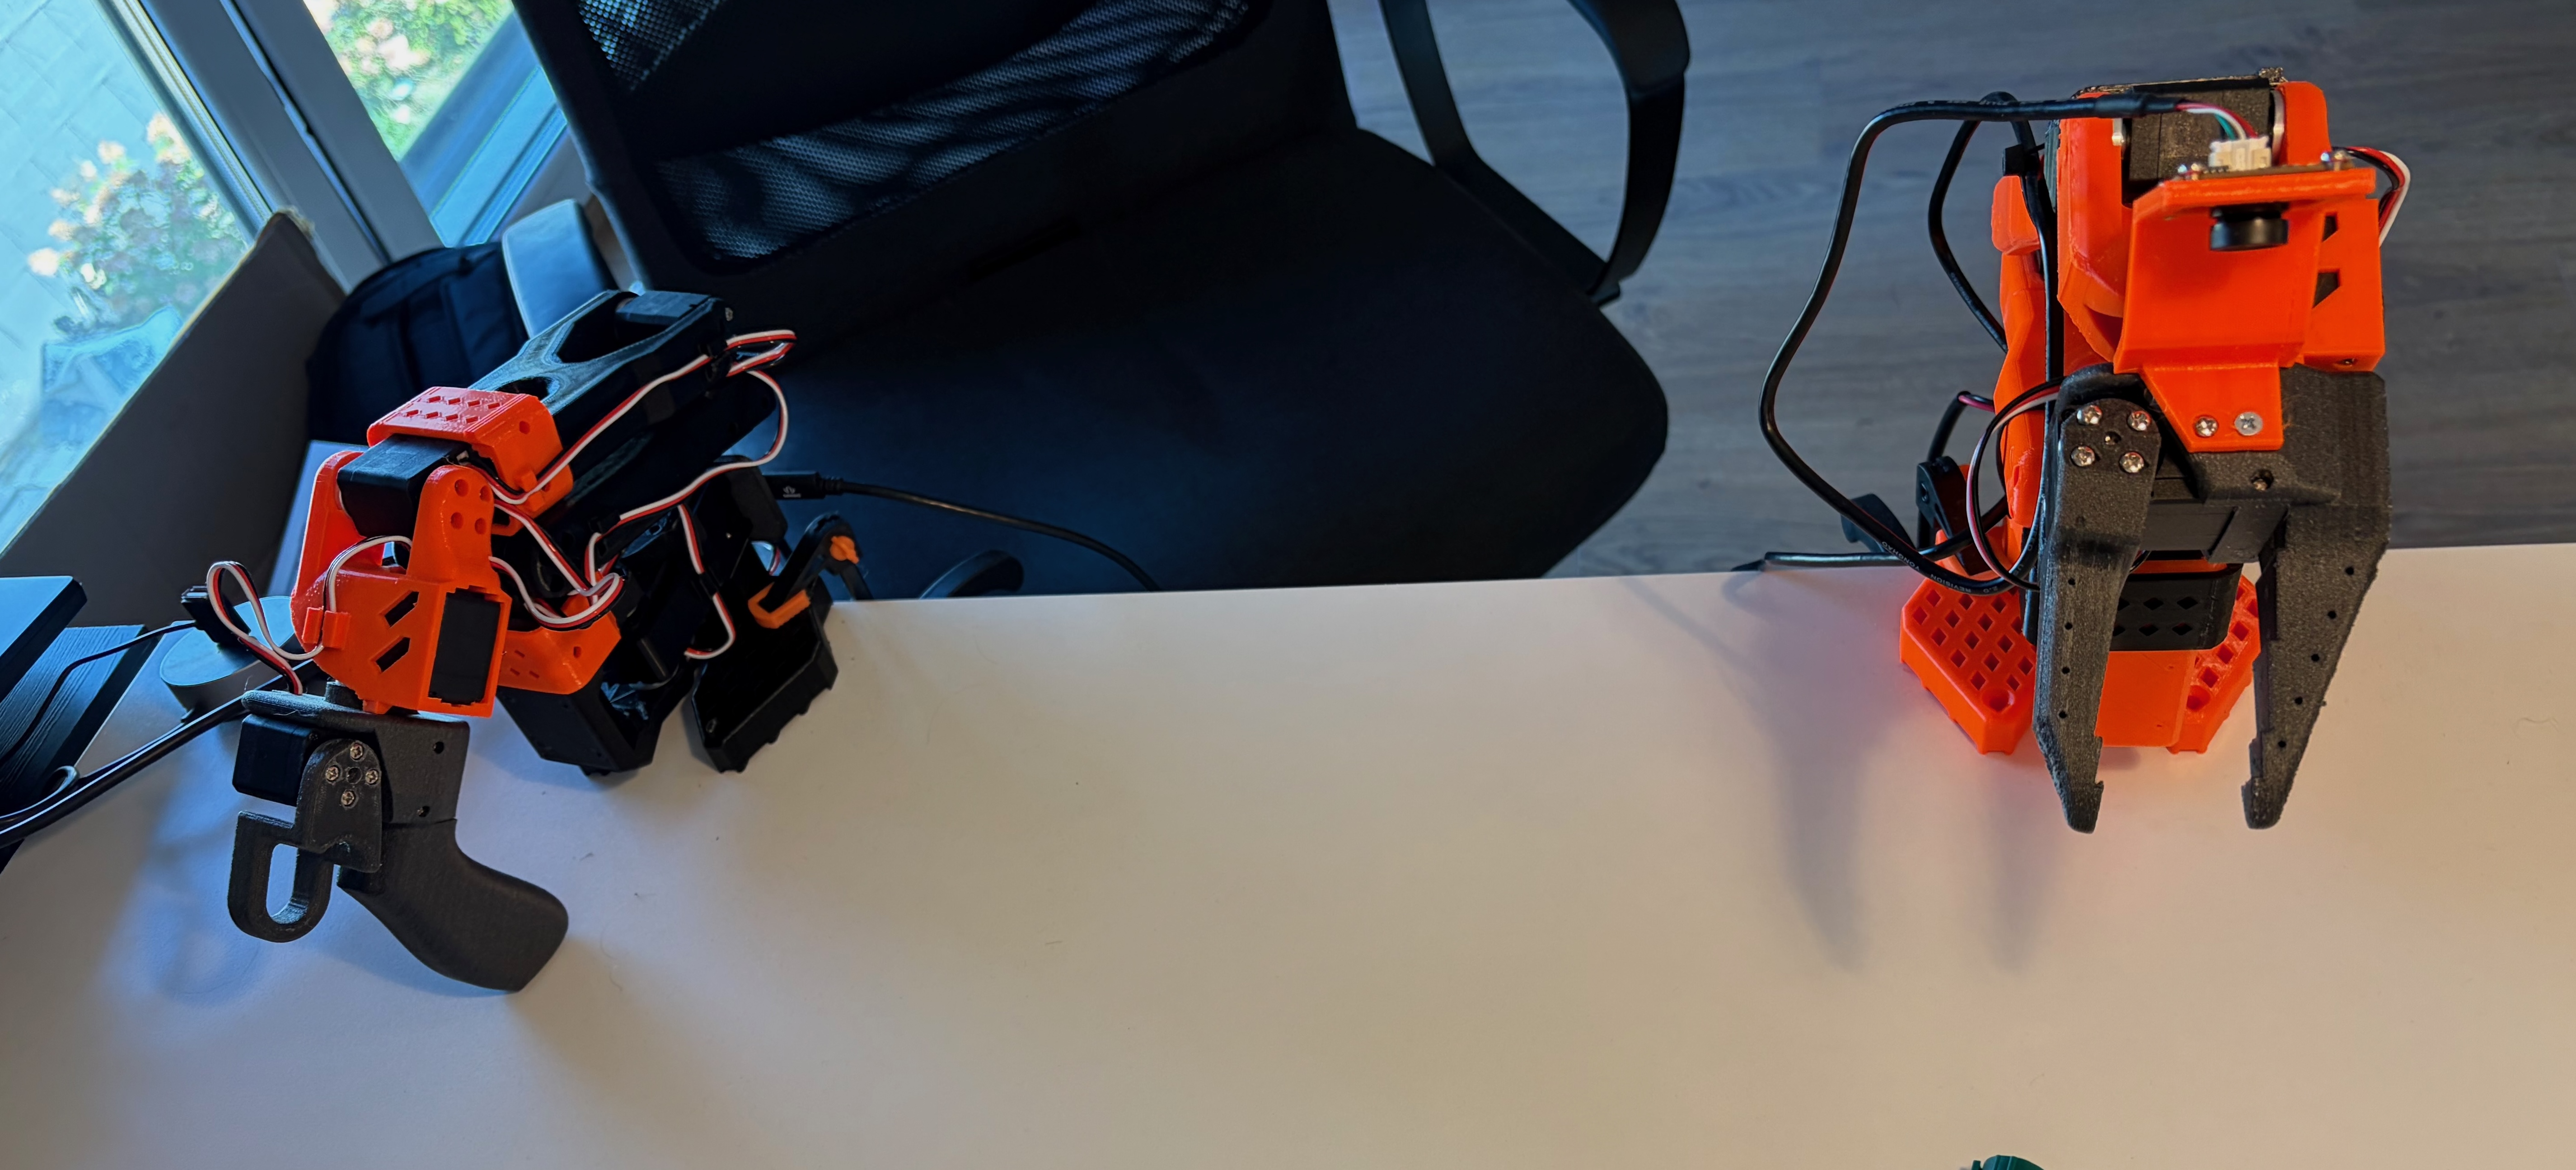
- Merry is the leader arm — the one that plans and leads the motion.
- Pippin is the follower arm — right there with him, and the one more likely to do something inadvisable out of curiosity.
They collect data together, get into the same jams, and later get separated so each can learn independently. Naming them that way is a joke, but it is also how I keep the roles straight.
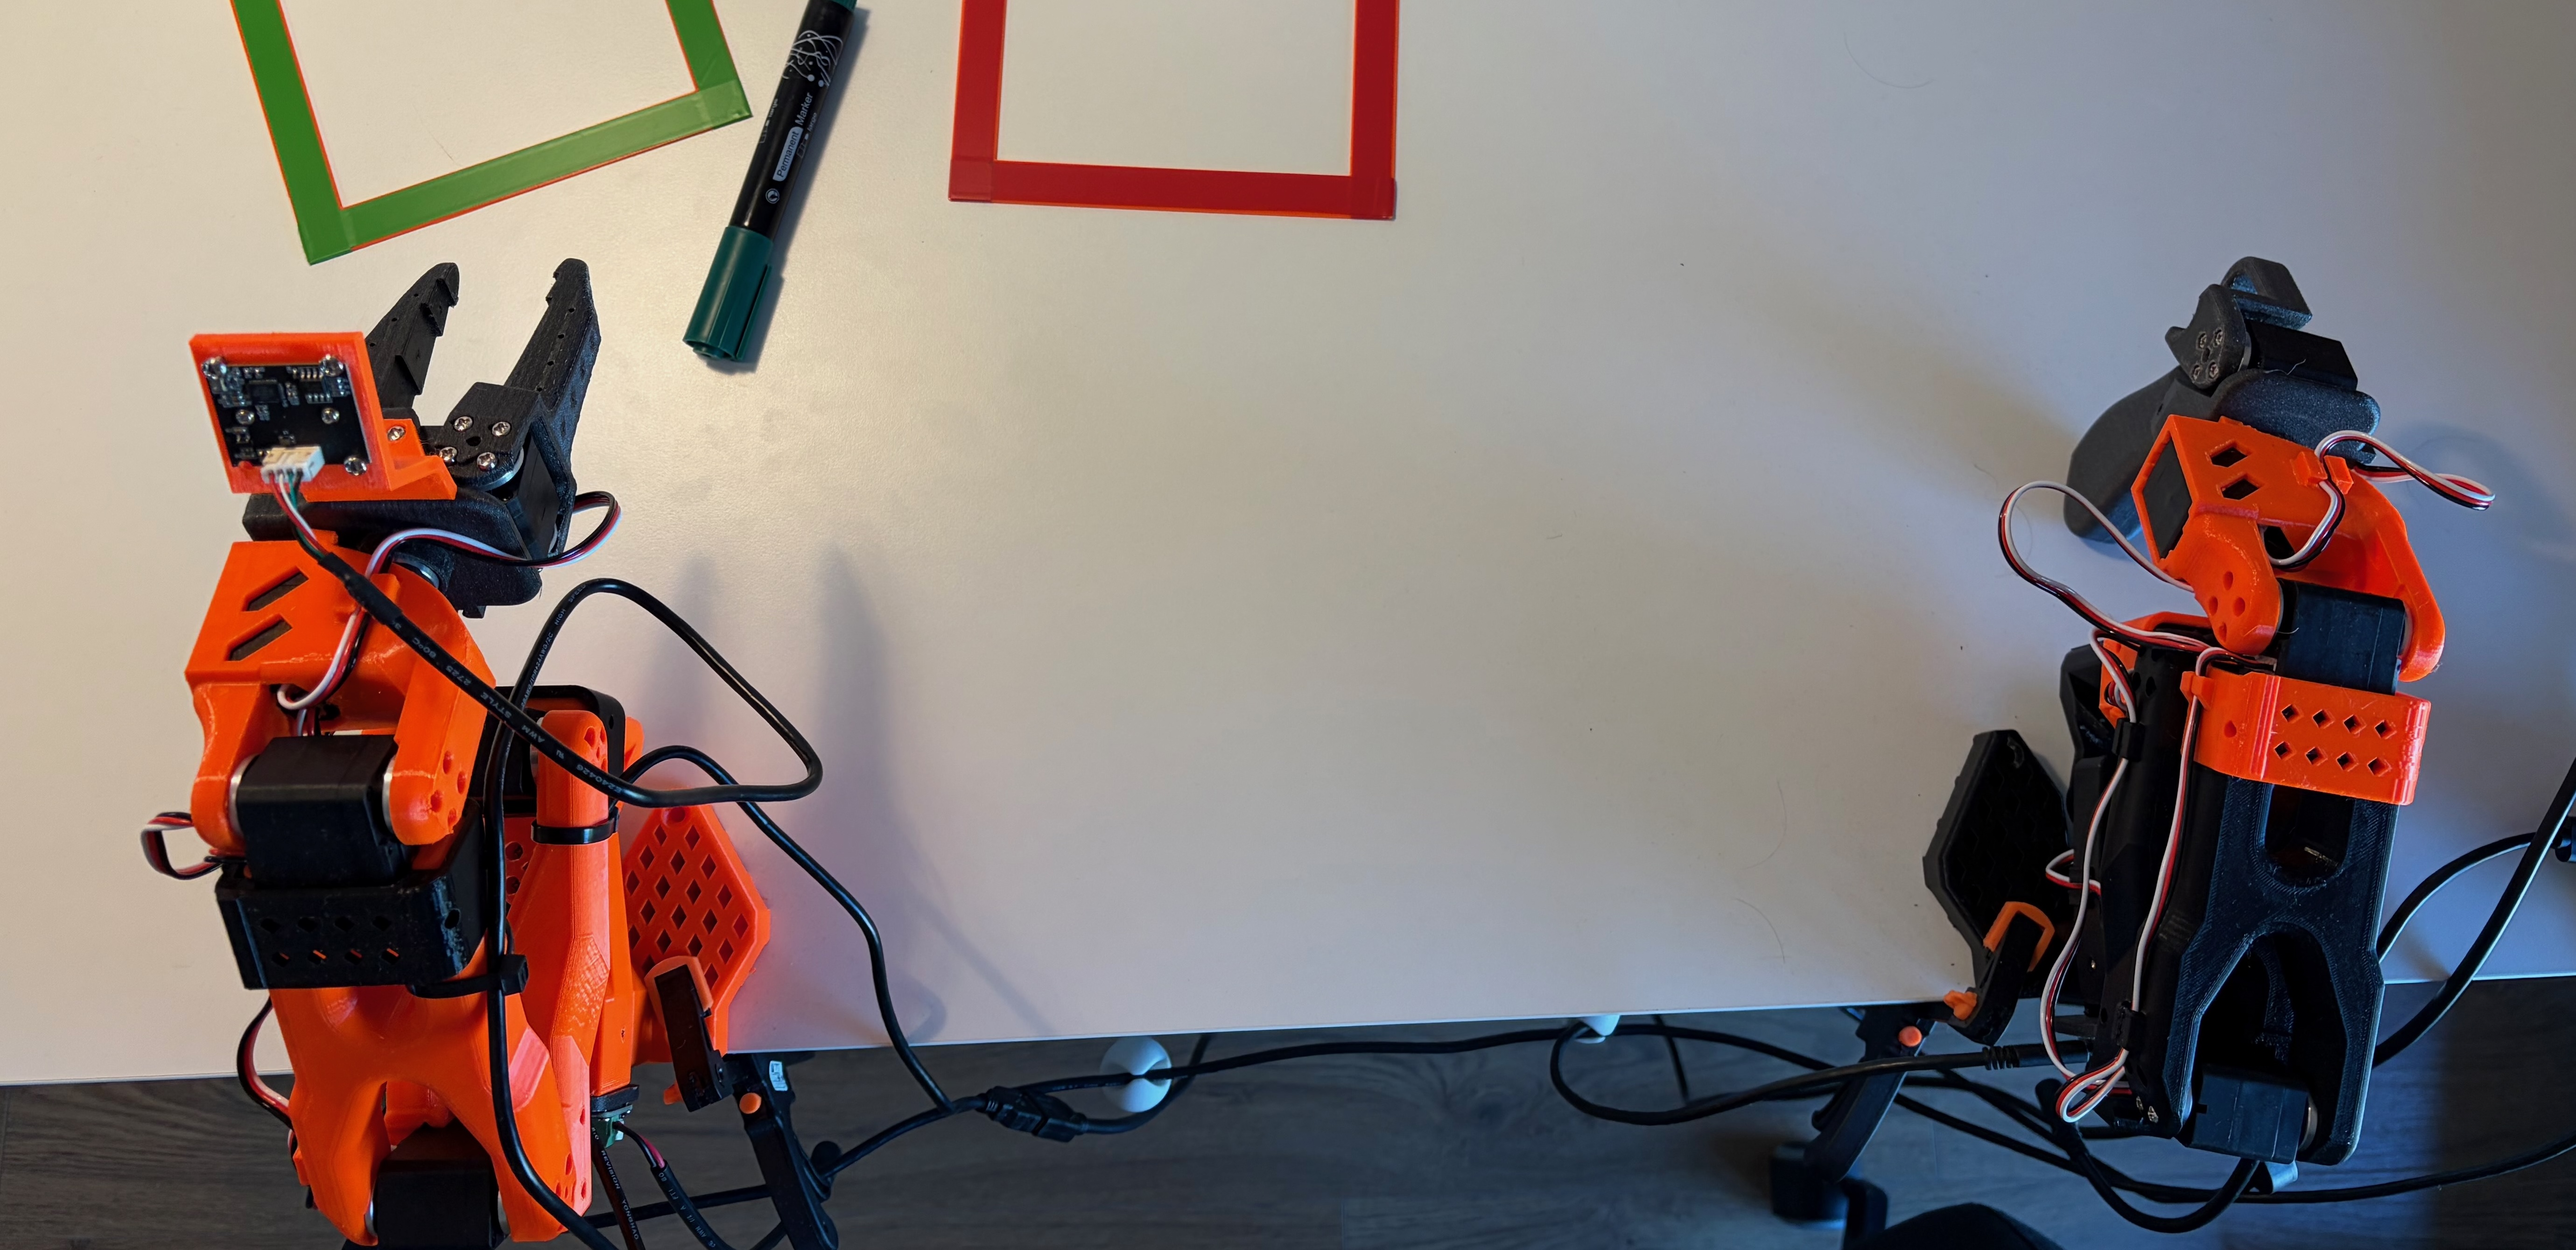
The writing is first-person and informal. The measurements should still be honest. If a run failed, the note should say so.
The first post is the starting plan: Building a Low-Cost Robot Learning Lab. Later notes will cover cameras, data collection, baselines, and debugging.