Merry'n'Pippin
RSS FeedA lab notebook for small-budget robot learning and vision-language-action experiments.
Hardware plans, training notes, datasets, and the runs that fail. Start with the lab plan or browse all posts.
Recent Posts
-
Can a Robot Learn 81 Pick-and-Place Routes from Only 25?
Testing whether ACT, SmolVLA, and π0.5 can generalize to novel cube-to-cup routes after training on only 25 of 81 start-goal combinations.
-
Teaching Merry and Pippin a New Trick
Training an ACT imitation-learning policy for 20,000 steps and turning SO-101 demonstrations into autonomous movement with LeRobot.
-
The Commands Behind My LeRobot Workflow
The command-line workflow I use to collect LeRobot datasets, train ACT policies, and run ACT or SmolVLA inference on my two-camera SO-101 setup.
-
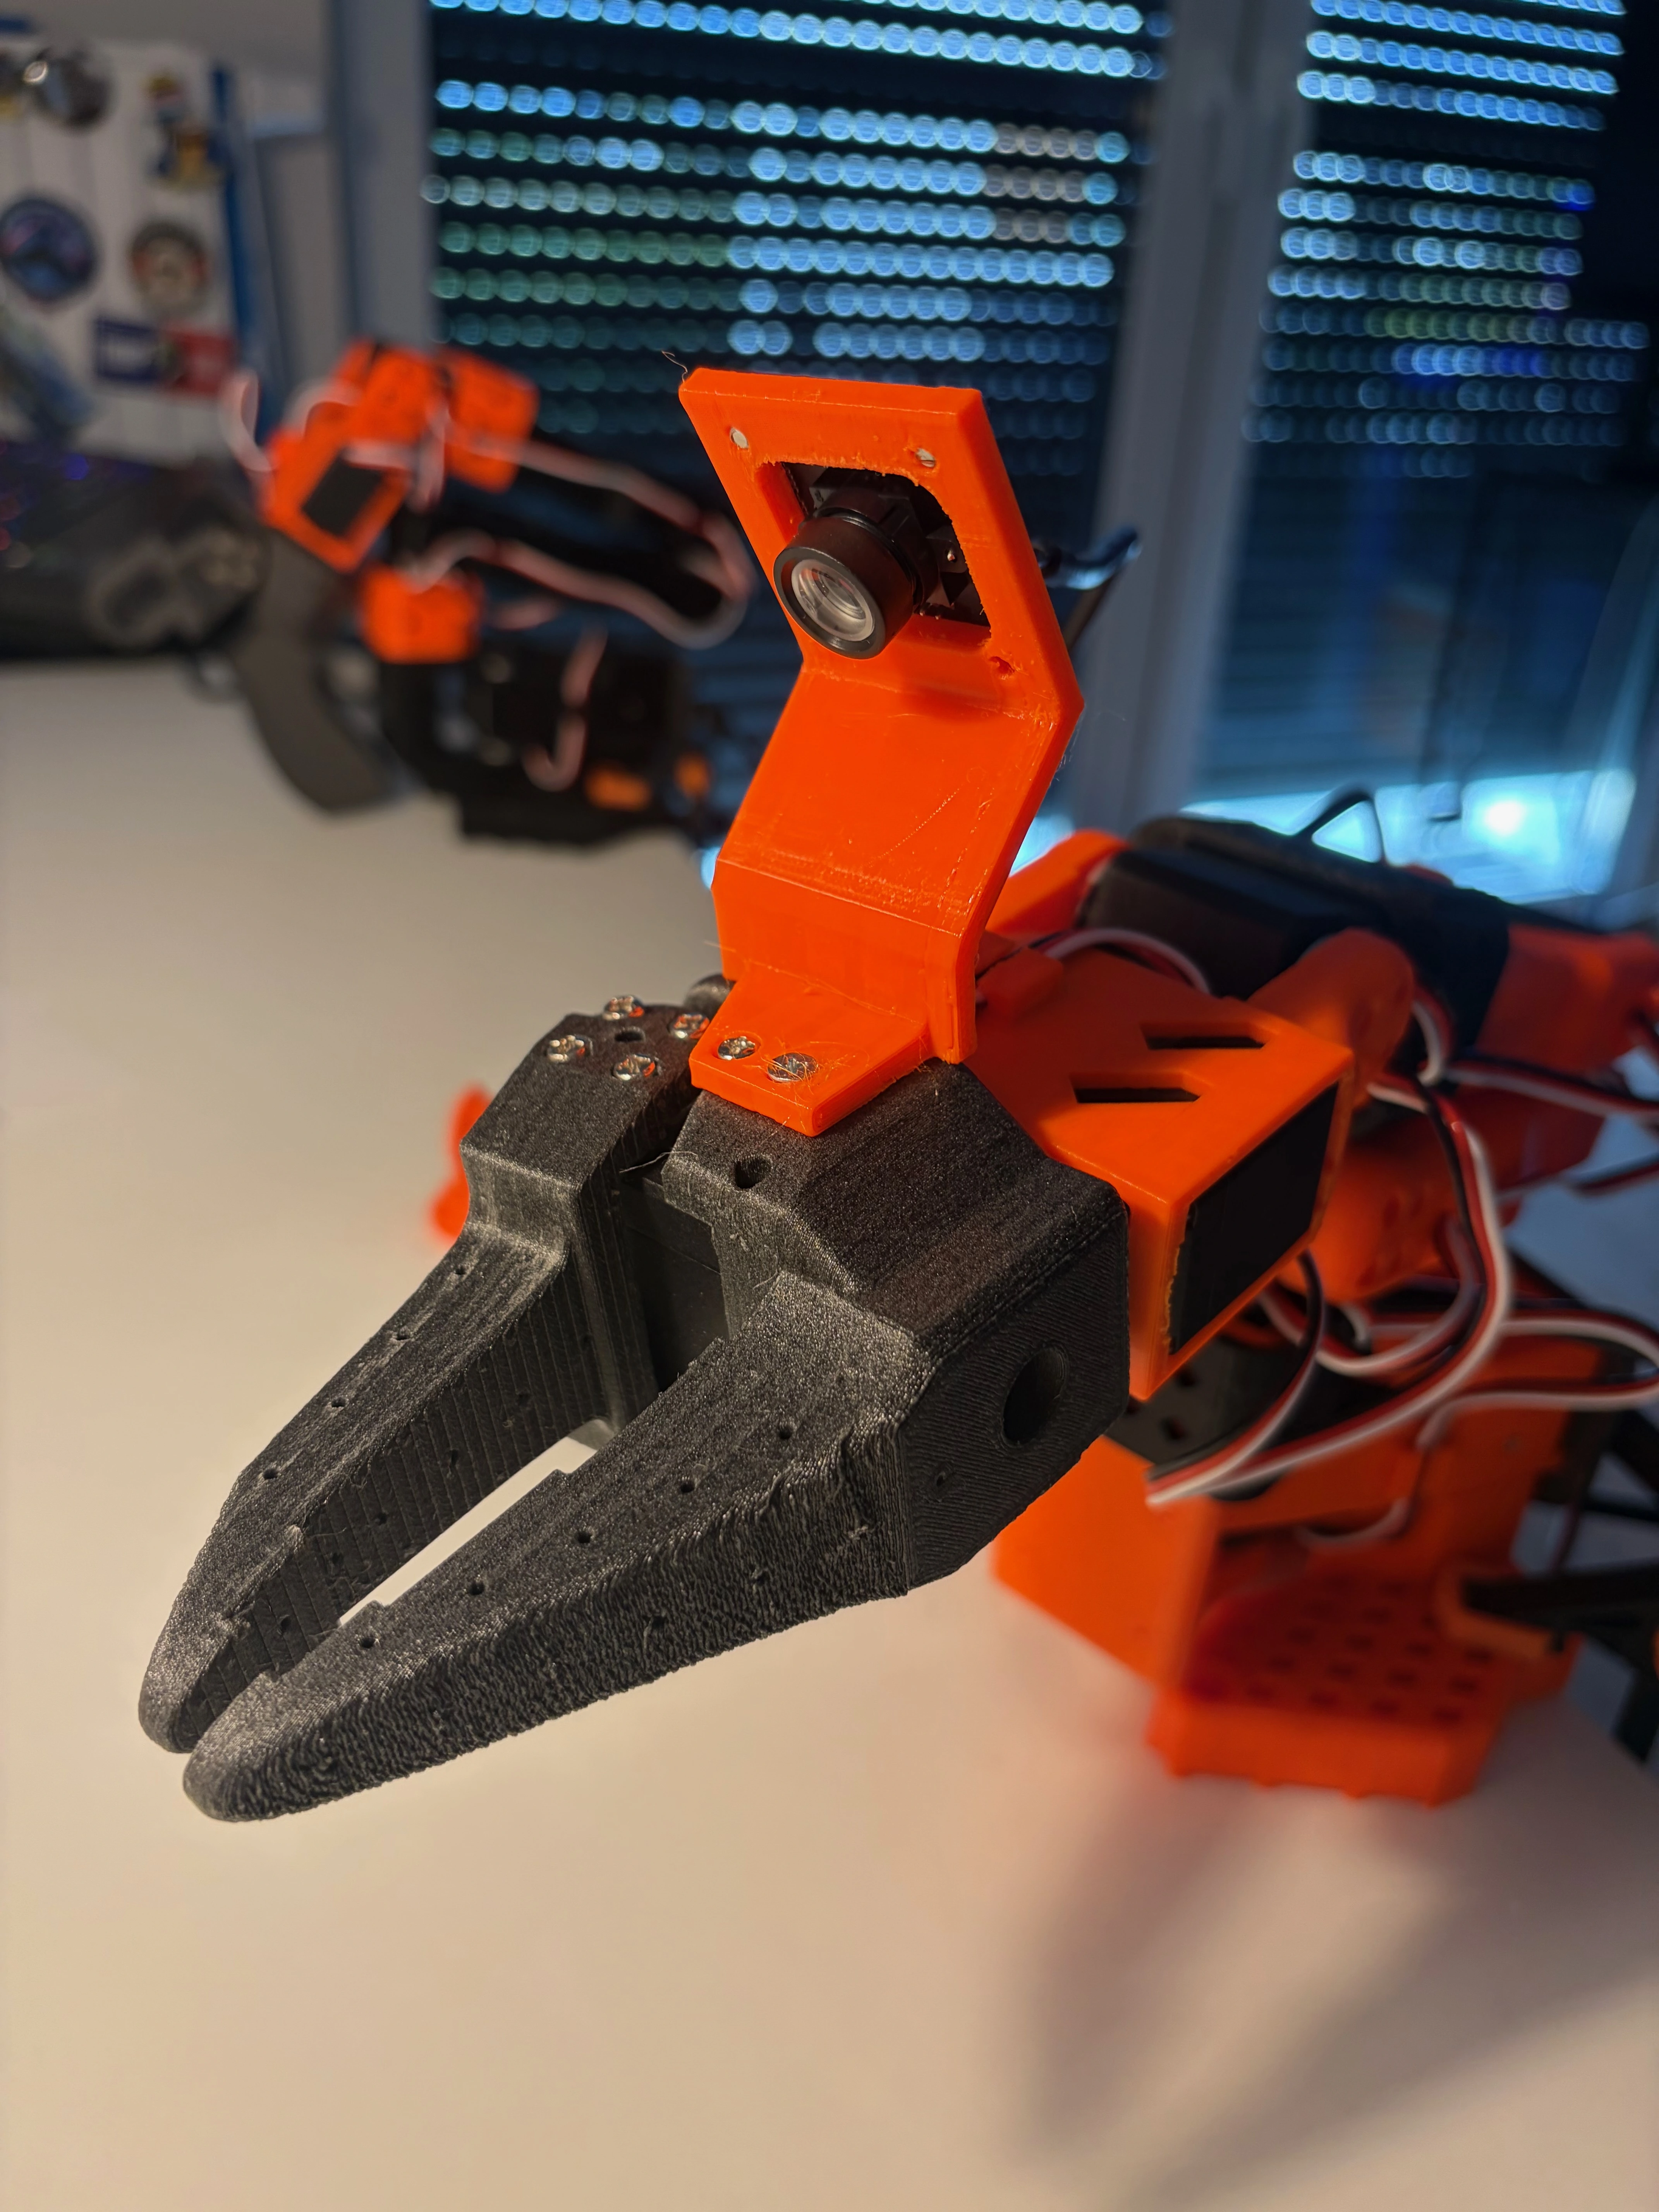
Giving My SO-101 Two Ways to See
How I equipped a LeRobot SO-101 with Logitech Brio 100 table cameras, a DFRobot FIT0701 wrist camera, and custom 3D-printed mounts.